Cobots made
in America.
Built on a proven cobot manufacturing platform — validated in the Chinese market and shipped to 100+ countries — now manufactured, assembled and supported from Dallas, Texas.
Dallas · Texas · Company Profile 2026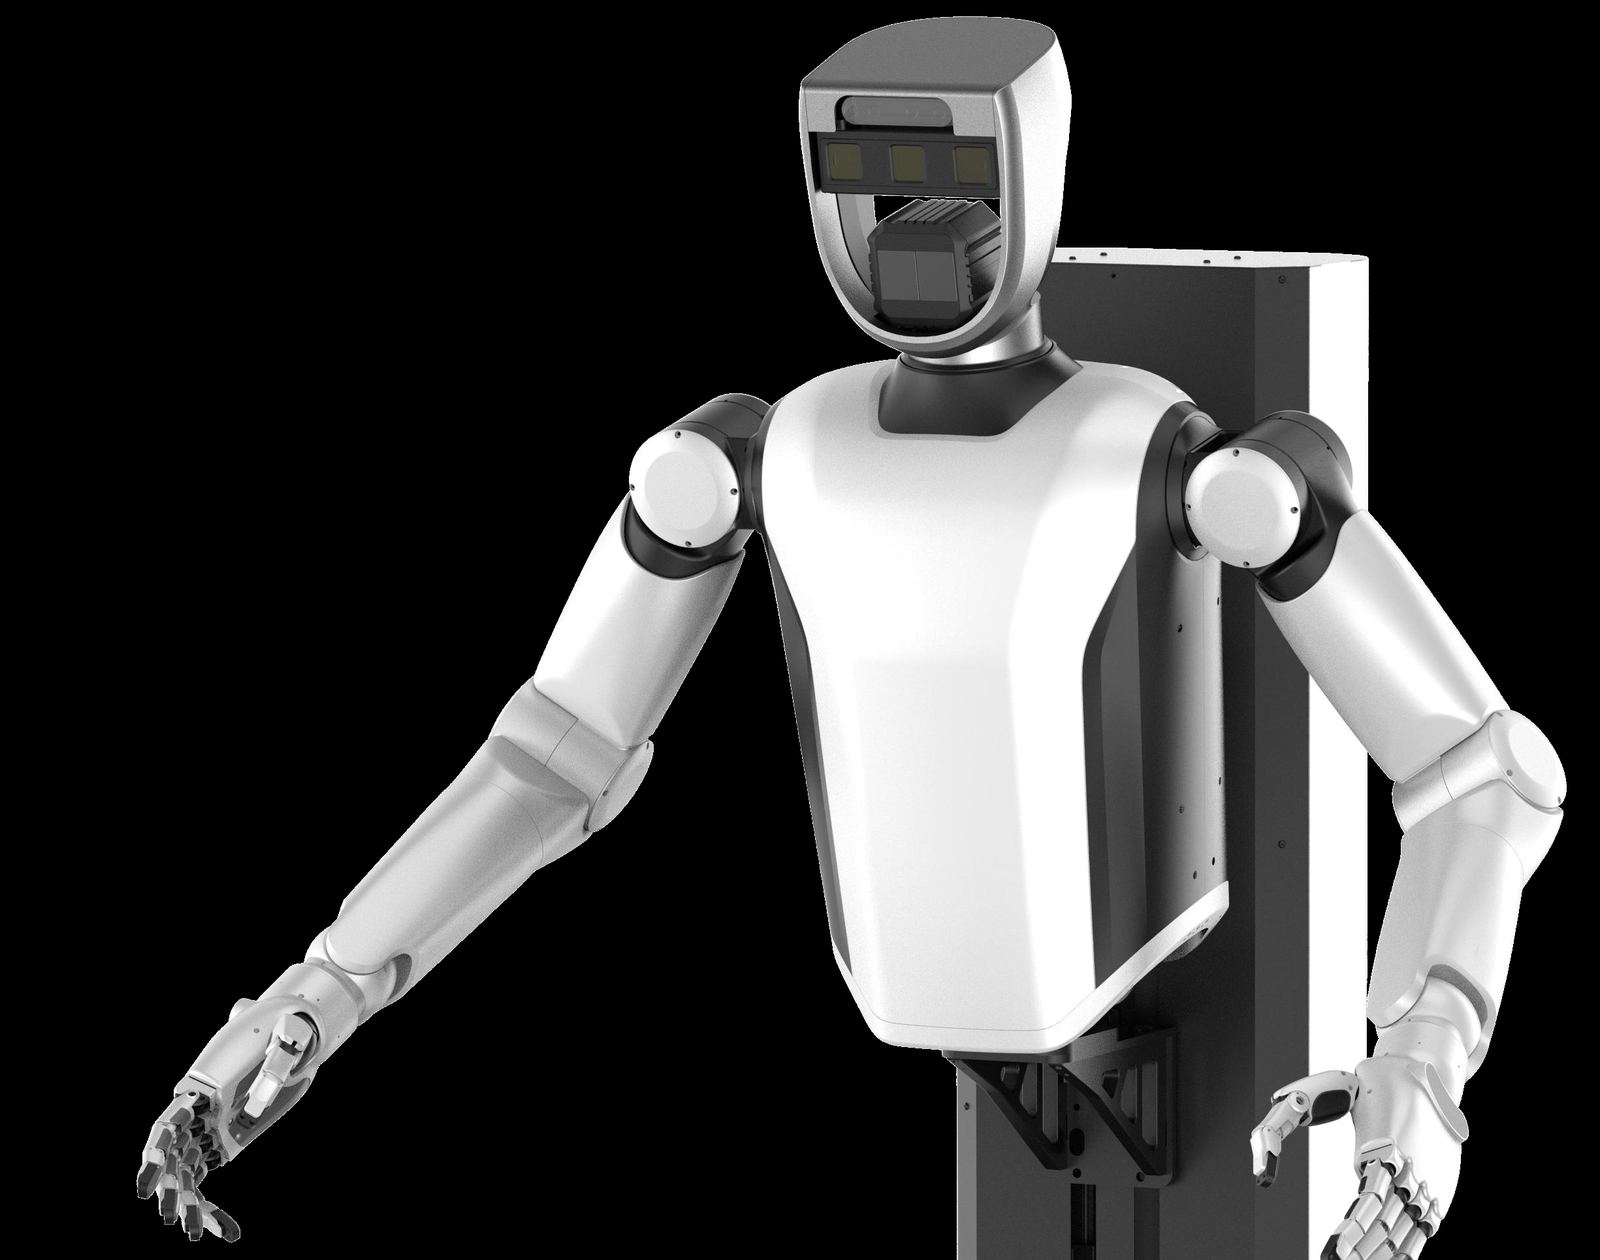
A proven foundation: China's leading cobot platform.
A cobot platform proven in the Chinese market, now developed and built in the USA. Parts are produced in Zibo, and all core components are developed in-house: joint modules, servo drives, control systems and software.
Built on the platform
Faonex is built directly on this platform — proven models, supply chain and software, now manufactured and supported in the USA.
Full in-house stack
Joint modules, servo drives, control systems and software developed and produced in house, not assembled from third-party parts.
Not prototypes
This means Faonex launches with field-proven products and a mature supply chain, not prototypes.
Made in America: local team + two U.S. factories
A partner team long settled in the U.S. runs Faonex day to day, localizing manufacturing of the proven platform in America — from robot arms to accessories.
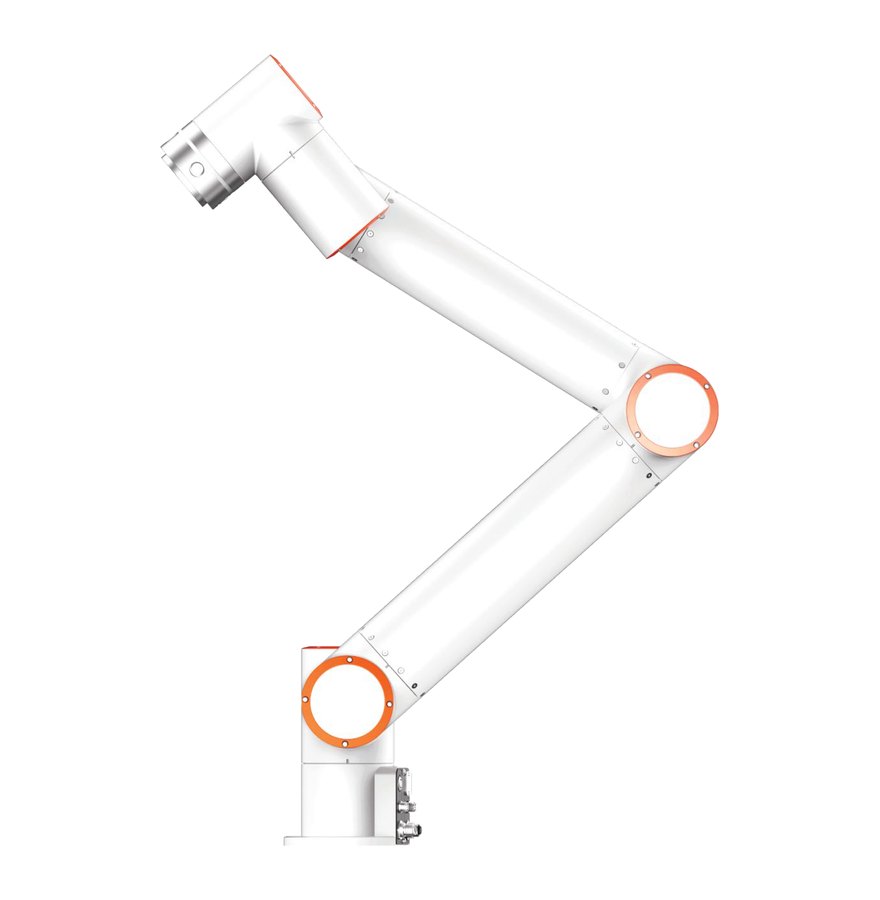
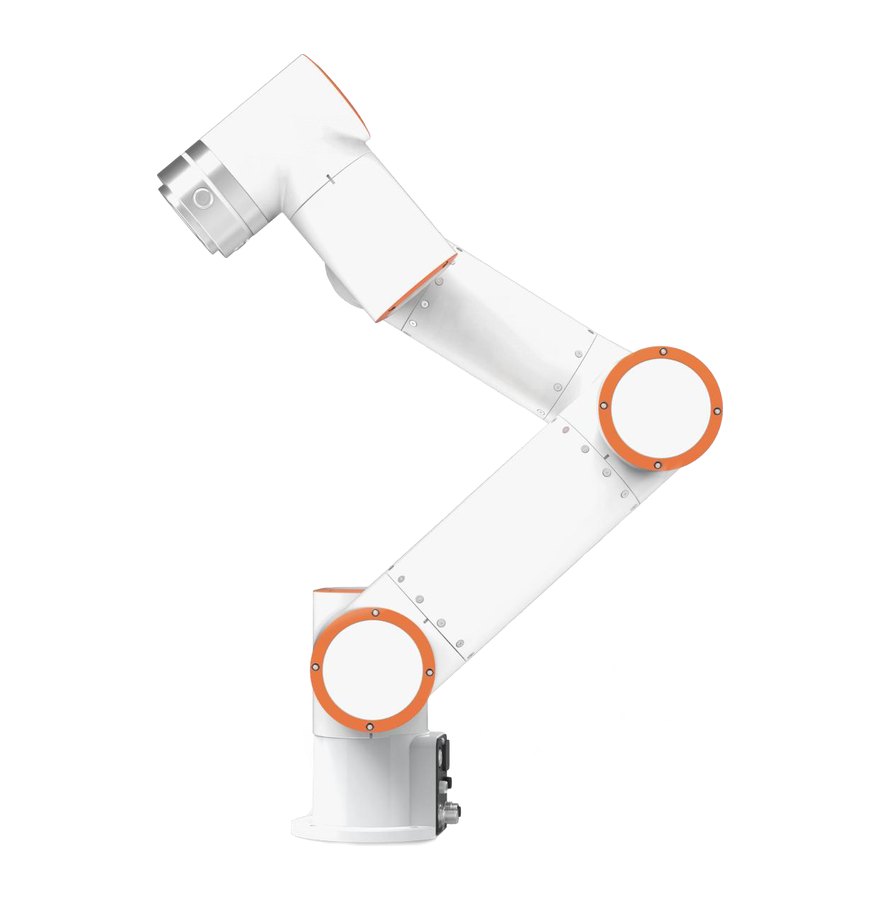
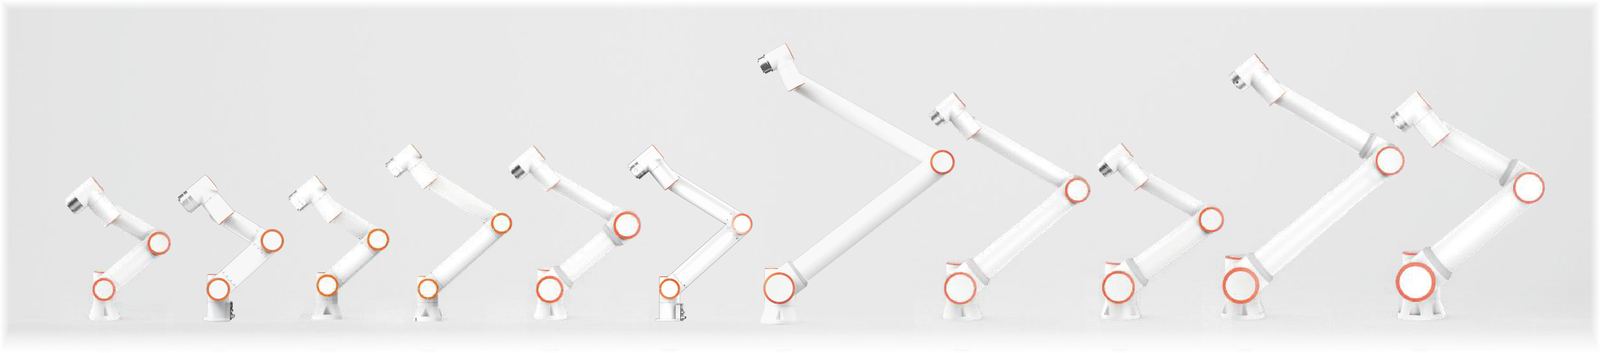
FX series cobots: 3–30 kg, one platform.
The FX series cobot family — payloads of 3–30 kg — plus joint modules, the ART 7-axis arm and humanoid upper-body modules. One architecture, so tooling, software and training carry across the whole range.
In-house core components, globally certified.
The parts that decide a robot's precision, safety and cost are ours — designed, built and certified in house.
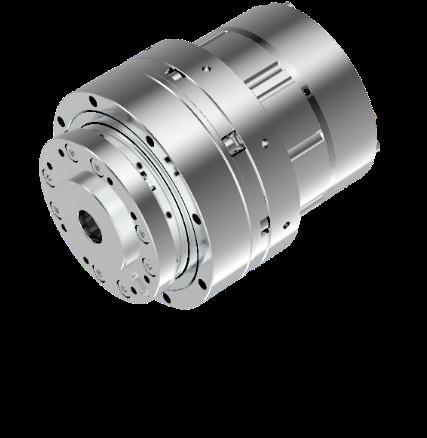
Joint modules
Modular, high-precision dual encoders with built-in torque sensing.
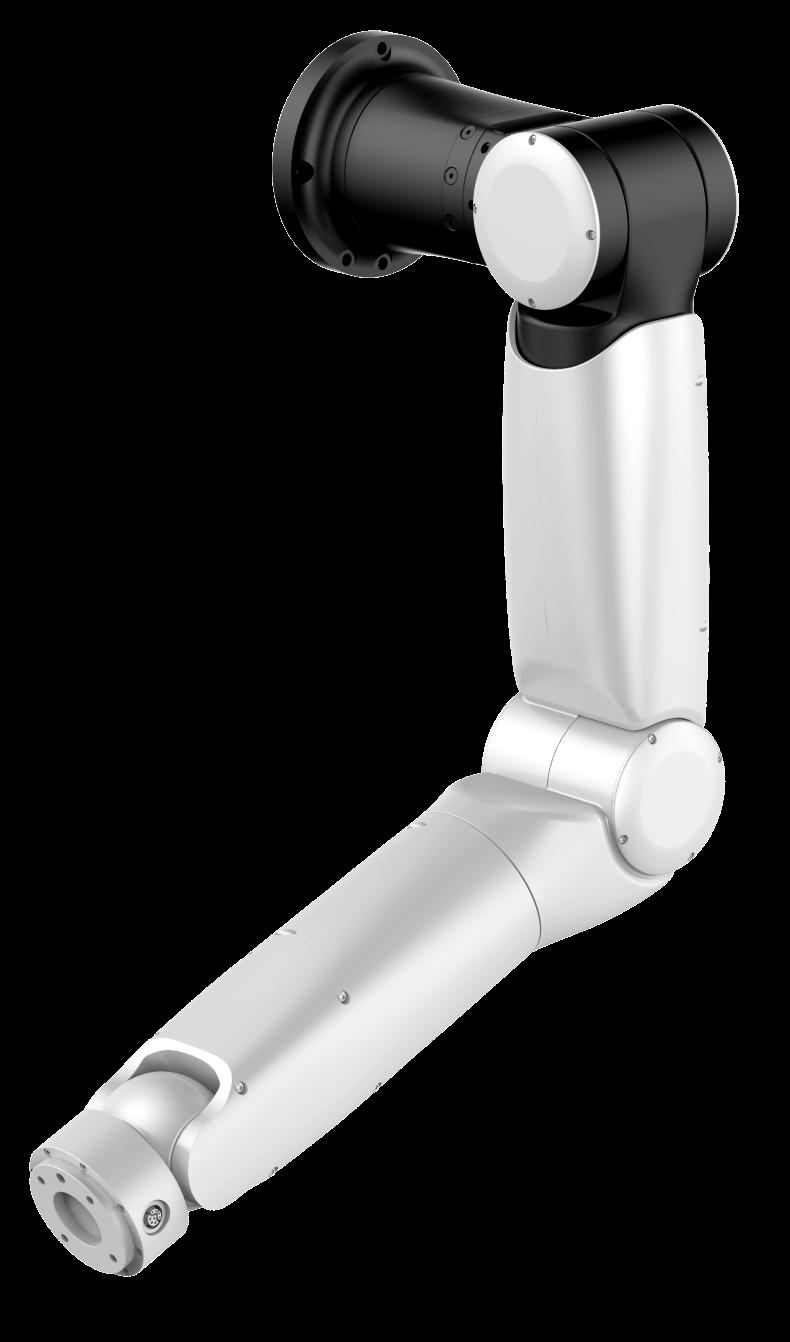
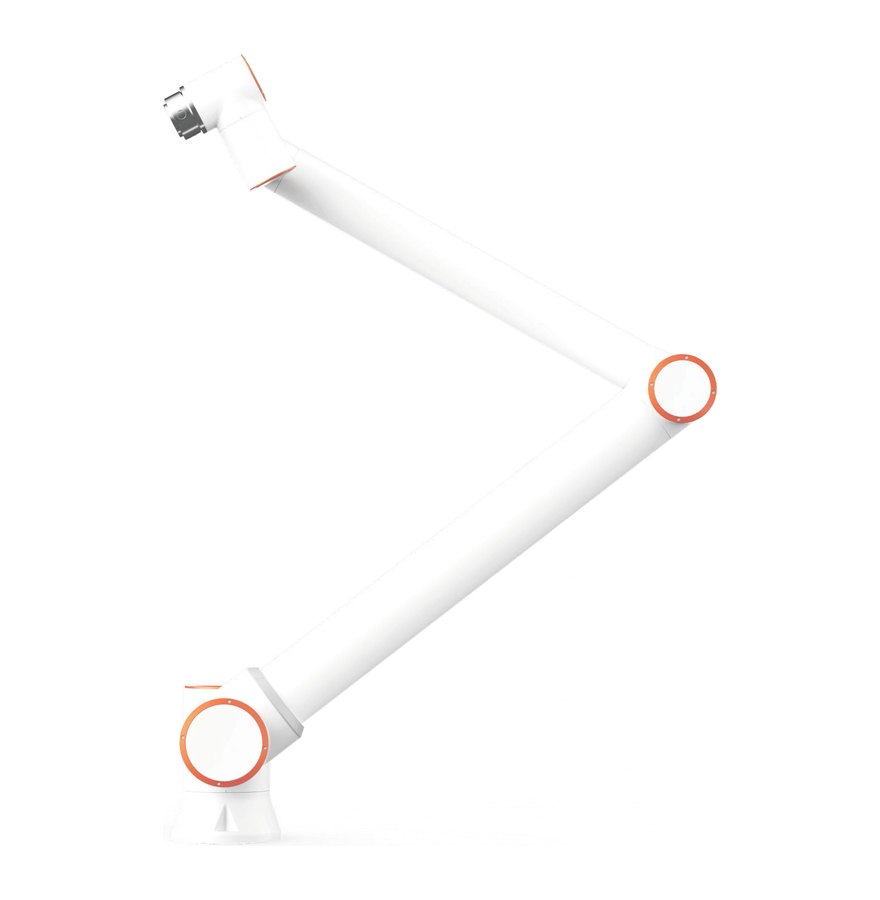
ART 7-axis arm
Lightweight 7-DOF design for humanoid and flexible tasks.
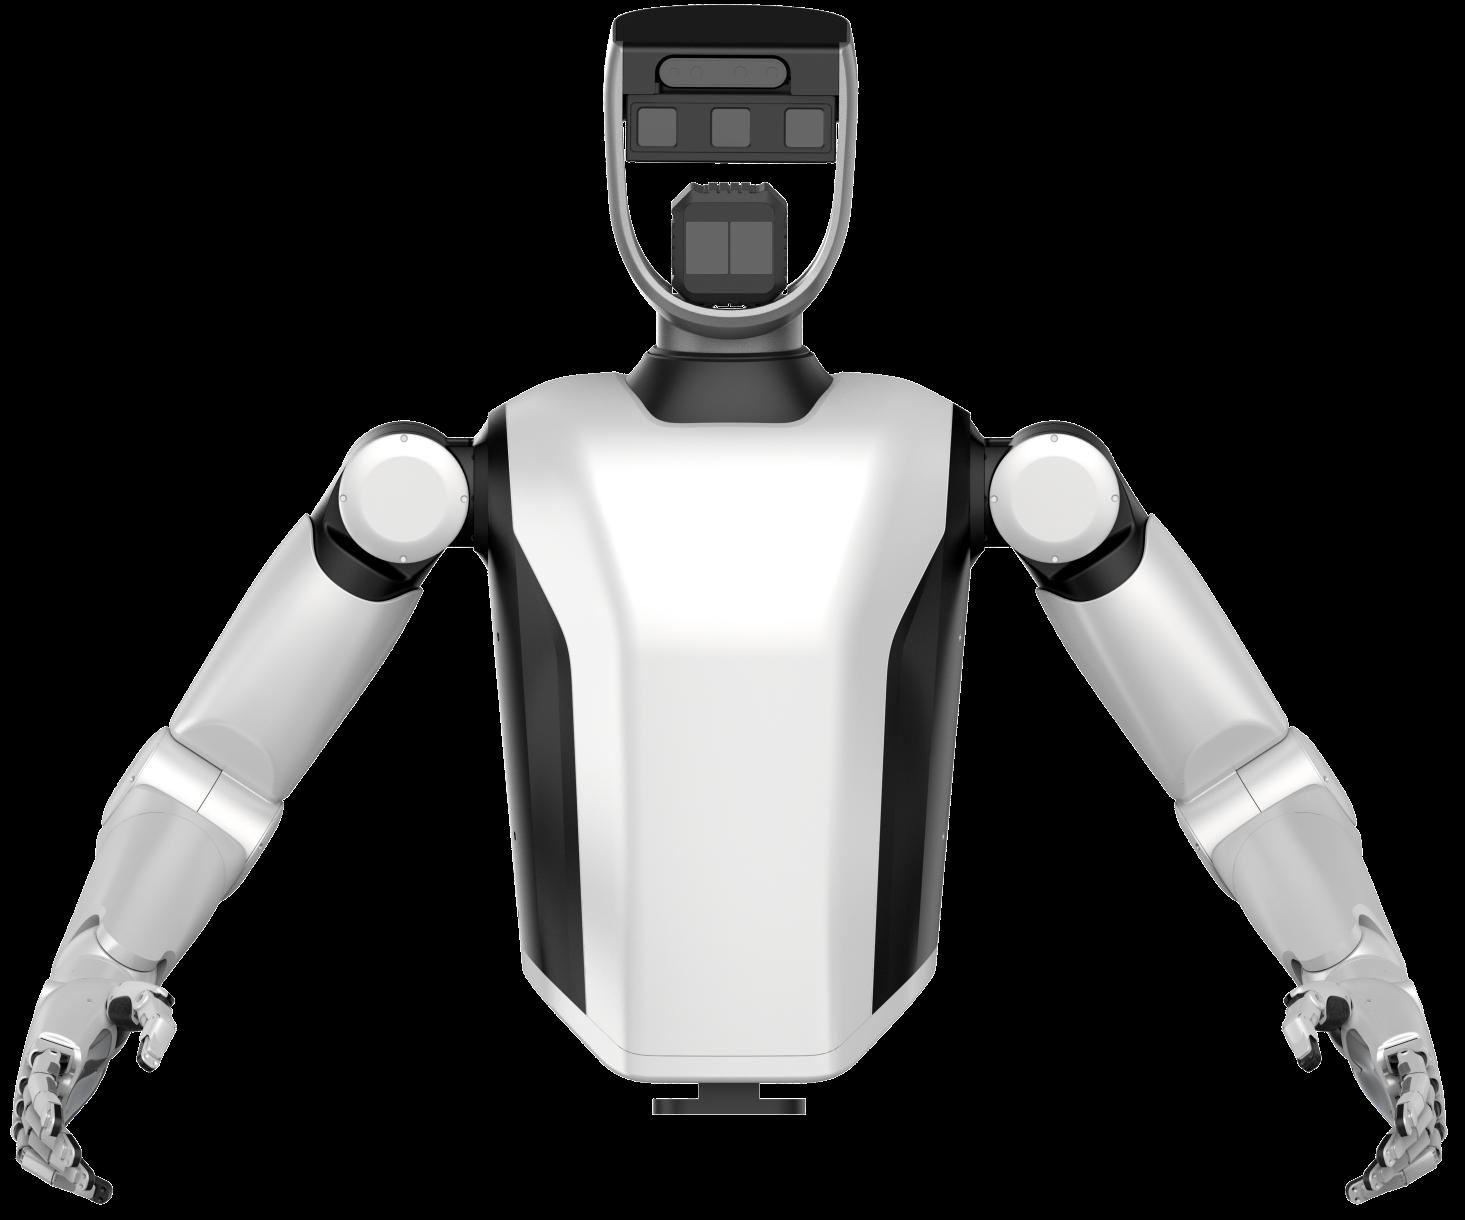
Humanoid upper-body module
A proven upper-body solution for humanoid robots, built on the same joint modules.
Product Certifications
Certified by leading international bodies for collaborative safety, functional safety and EMC, and ready to deploy in the U.S. and EU markets.
Embodied AI hardware: vision helmet, dexterous hand and more.
A full-size humanoid platform, teleoperation hardware and dexterous end-effectors — the physical layer for embodied-AI research and data collection.
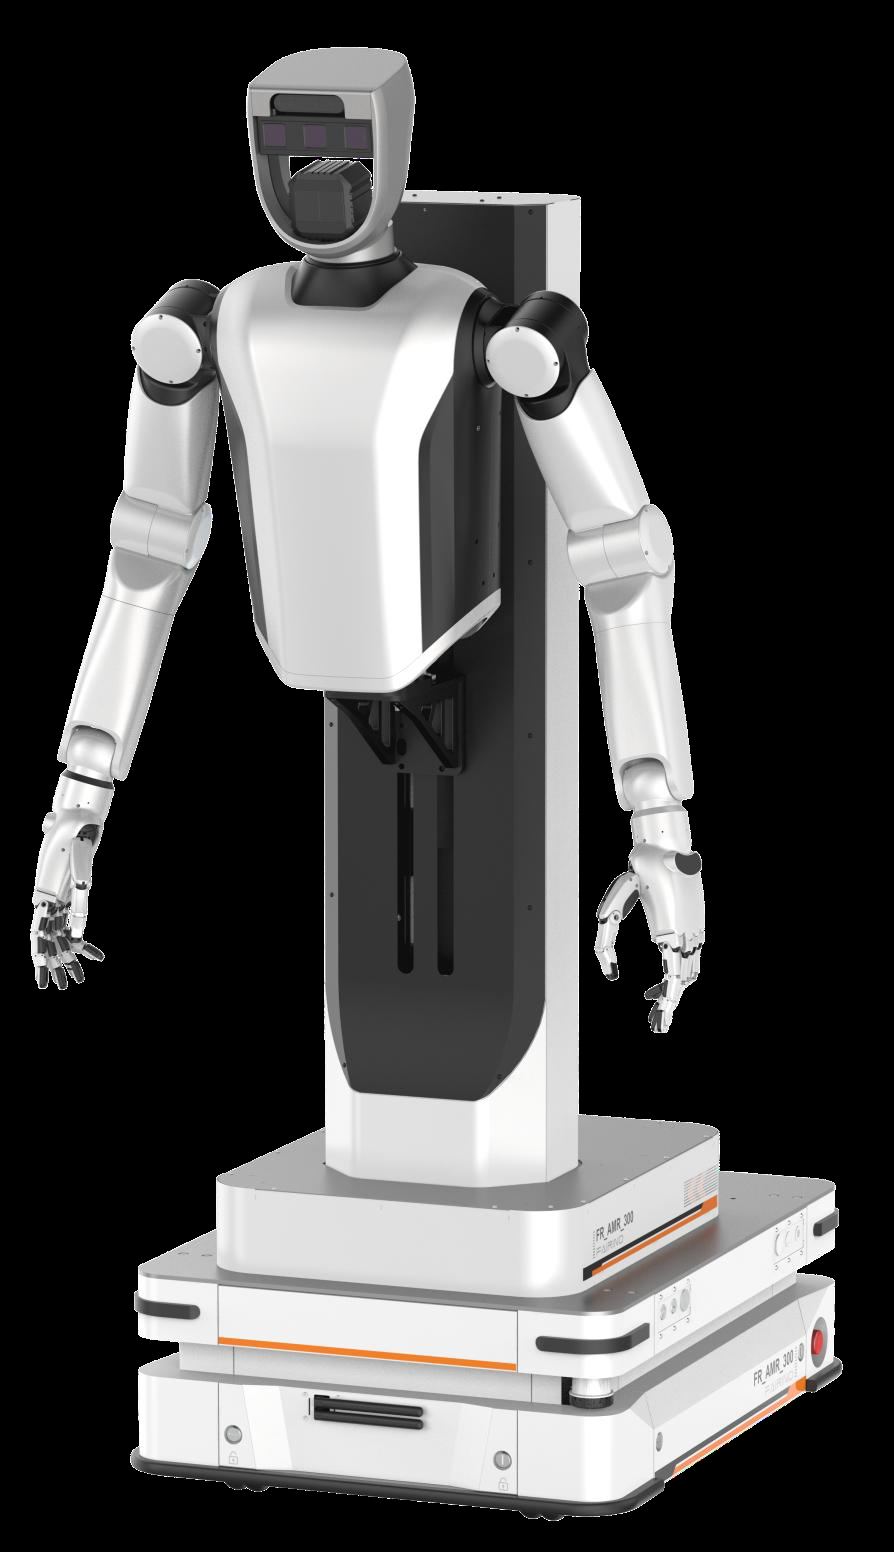
Complete humanoid robot
A full-size humanoid platform built on in-house joint modules, for embodied-AI R&D and data collection.
- 01Vision helmet — AR / 3D vision teleoperation helmet for immersive teleoperation, demonstration capture and embodied-data collection.
- 02Dexterous hand — multi-DOF dexterous hand for fine grasping and teleoperation tracking, a core actuator for humanoid robots.
- 03Joint modules & accessories — joint modules, harnesses and accessories all developed in-house, with 300,000 sets/year capacity.
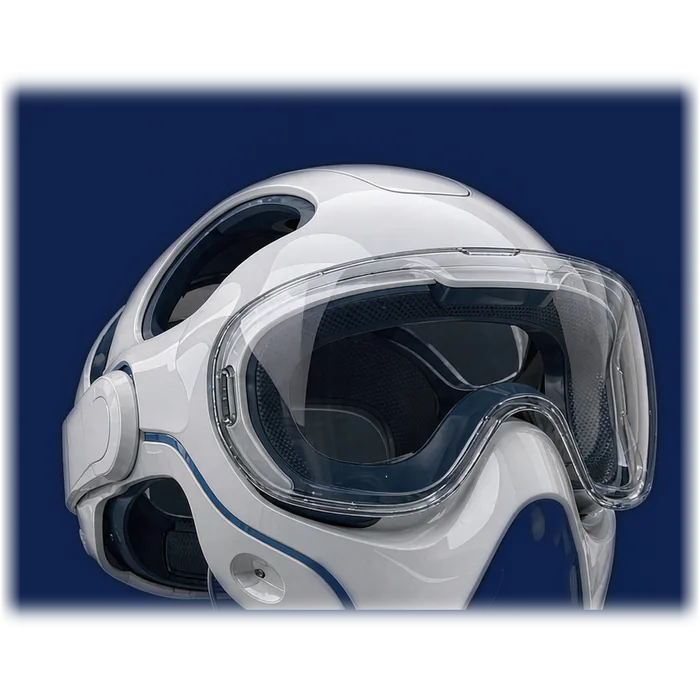
Vision helmet
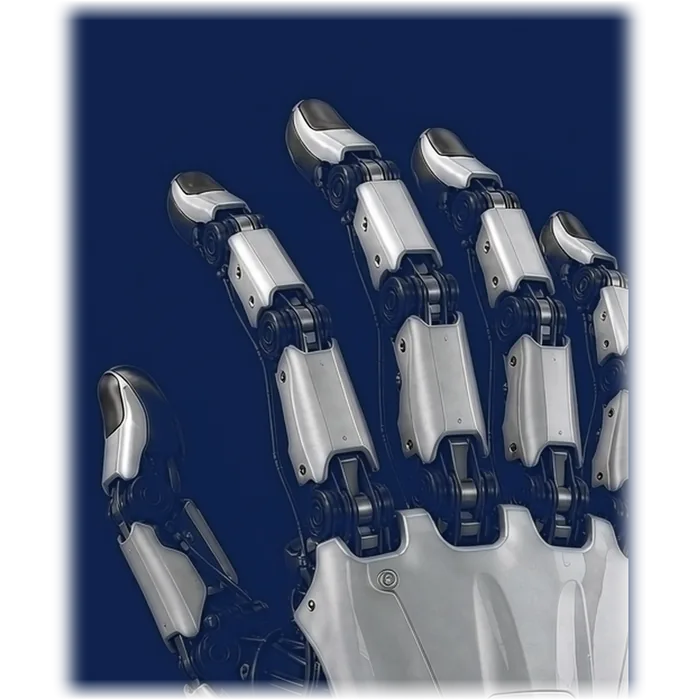
Dexterous hand
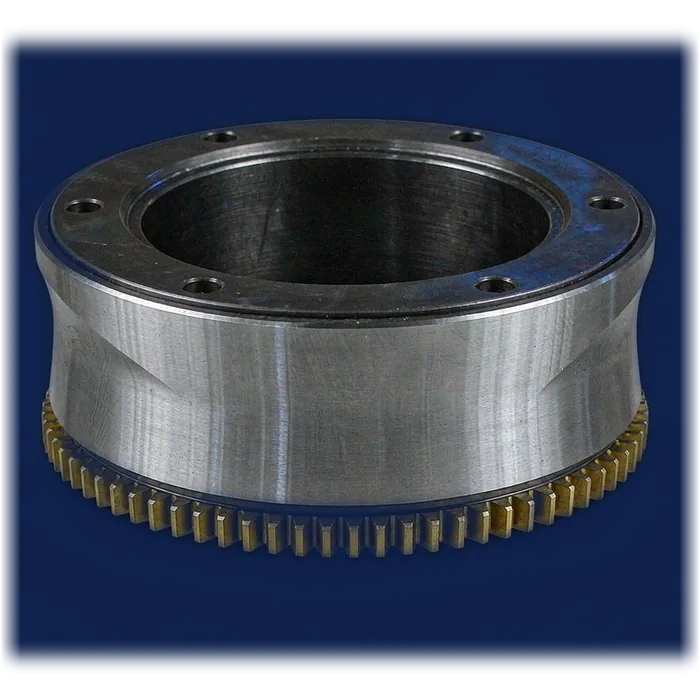
Joint modules & accessories
Embodied-AI software stack: five layers, closed-loop evolution.
A data engine and software stack — a complete loop from teleoperation capture to policy training and deployment.
- L5Applications & skillsDual-arm assembly and inspection · bin picking · palletizing and handling — the skill library keeps growing.
- L4Foundation modelsGR00T VLA policy for task-conditioned action generation · SAM visual perception and segmentation.
- L3Data engineIsaac Sim synthetic scenes and auto-labeling · Cosmos world models · real-robot teleoperation demos.
- L2Runtime & middlewareIsaac ROS + CUDA-X for inference, perception and control · Isaac Lab training and evaluation.
- L1Compute & hardwareGPU training workstations · Jetson edge compute · robot bodies and multimodal sensors.
Closed-loop evolution: field data → data engine → model updates.
Sim-to-real in five closed-loop stages: a deliverable at every step.
Five repeatable stages, each with a clear deliverable (KPIs / digital twin / checkpoint / benchmark / runtime) — acceptance is evidence-based and issues trace to a single stage.
Scope
Task breakdown, environment specs and quantifiable success criteria.
Twin
Build a digital twin in Isaac Sim; generate synthetic video and trajectories with Cosmos.
Learn
Post-train the GR00T policy; integrate the SAM perception pipeline.
Verify
Closed-loop benchmarking in Isaac Lab; sim-to-real consistency validation.
Go live
Isaac + Jetson runtime; dual arms execute tasks in real time.
Closed-loop feedback: field data flows back into S2 simulation and S3 training. Deployment is not the finish line, but the start of the next iteration.
Data platform: 1 foundation · 4 modules · N terminal types.
Scene import → collection → auto-labeling → cleaning and QA → training and evaluation → real-robot deployment, with field data feeding back in a closed loop.
Data foundation
Unified storage and compute: all data assets managed centrally, searchable and traceable.
Core modules
Collection · labeling · cleaning · QA — an automated pipeline that delivers training-ready data.
Connected terminals
Humanoids · dexterous hands · teleoperation devices · first-person cameras: synchronized multi-source ingestion.
Global dashboard
Real-time monitoring of data volume, device status and task progress.
Task management
Create collection tasks, assign staff and track progress.
Cleaning & labeling
Image compression · timestamp alignment · semantic tags.
QA & export
Quality scoring · pass-rate comparison · export to training formats.
Data capture and conversion: from human demos to training-grade assets.
Each step works standalone or chains into a complete data pipeline — task orchestration, multimodal clock sync, automatic cleaning, quality checks and dataset versioning.
01 · Mocap manipulation data
120 Hz optical and inertial fusion mocap with 22 synchronized RGB-D cameras; sub-millimeter hand-object trajectories across 21 grasp types (Cutkosky taxonomy); occlusion-resistant, uninterrupted tracking.
02 · 4D dynamic scenes
60 Hz dynamic 4D Gaussians, ~150K points per frame; 2.4 mm object reconstruction error; render from any viewpoint, so camera setups can change without re-capture.
03 · First-person auto-labeling
Ordinary video in, training-grade labels out: 21-keypoint 3D hand pose plus per-frame pose; hand-shape parameters, action semantics and hand-object contact, delivered as structured JSON.
04 · Demonstration transfer
Human demo → physics refinement of the hand model → dexterous-hand simulation → real-robot execution; simulated success rate rises from 7.3% to 67.9%, and one demo transfers to multiple dexterous hands.
05 · Teleoperation teaching
Direct leader-follower mapping across the full joint range; continuous recording of joint and manipulation trajectories; hardware, teleoperation pipeline and task-pipeline post-processing integrated.
06 · Dataset delivery
Six field groups (action, state, vision, task, policy, quality); contact-annotated and indexed by embodiment; Lance / Parquet export plugs straight into training workflows.
Three production sites across two continents.
Chinese-scale parts manufacturing combined with U.S. assembly and printing — Zibo parts plant (China) · U.S. cable plant · Dallas 3D printing factory.
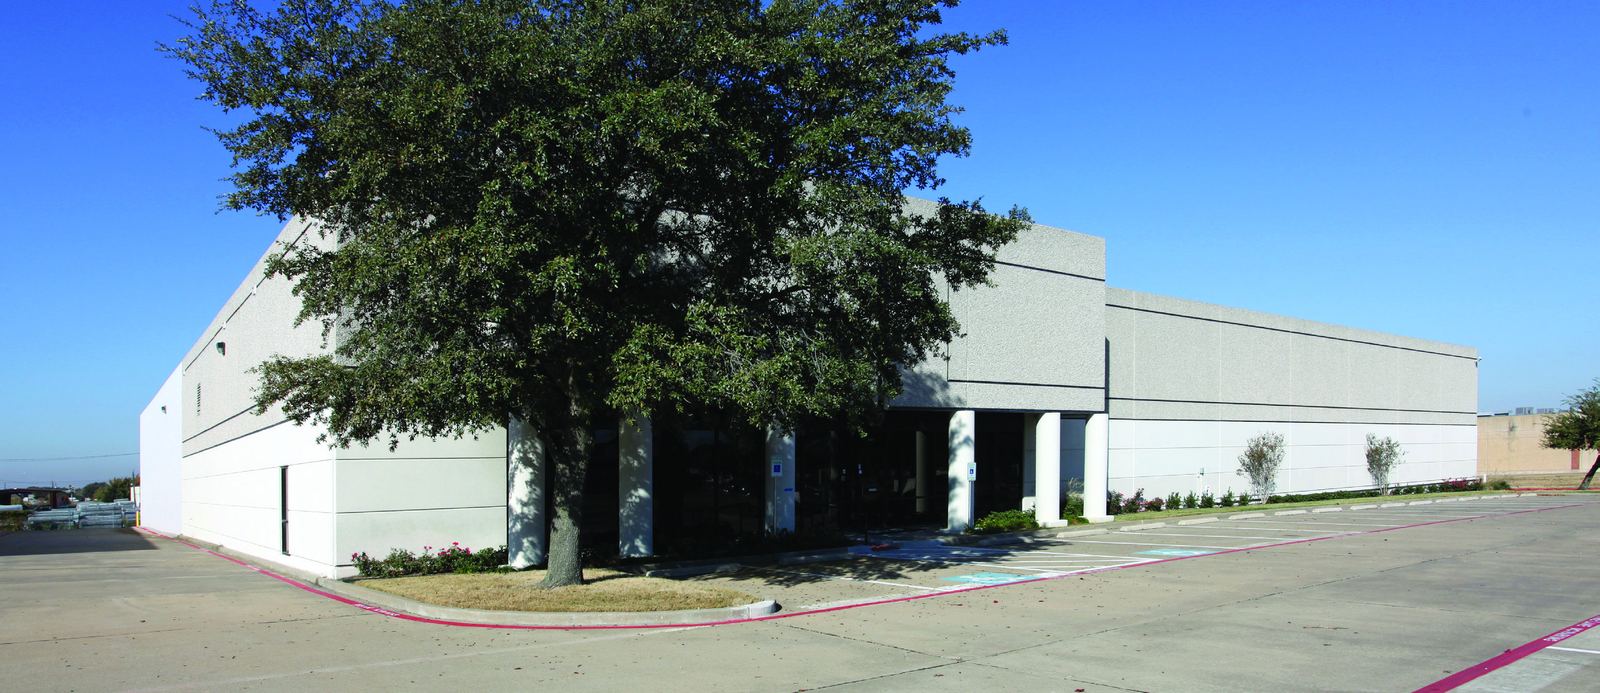
Dallas 3D printing factory
Site area 40,000+ sq ft · 30+ printers targeted by end of 2027 · 20,000+ 3D-printed parts per year.
- 01Zibo parts plant · China — FX series cobot and joint-module assembly, the parts backbone for U.S. lines, with annual joint-module capacity of 300,000 sets.
- 02U.S. wire & cable plant — U.S.-made robot harnesses and cables, securing the American supply chain for Faonex production and service spares.
- 03Dallas 3D printing factory — U.S. 3D printing and final assembly, built to customer demand.
Chinese-scale parts manufacturing + U.S. assembly and printing.
A broad, mature installed base.
Welding, CNC machine tending, picking, palletizing, commercial services, wellness and more — deployed and supported in production, not pilots.
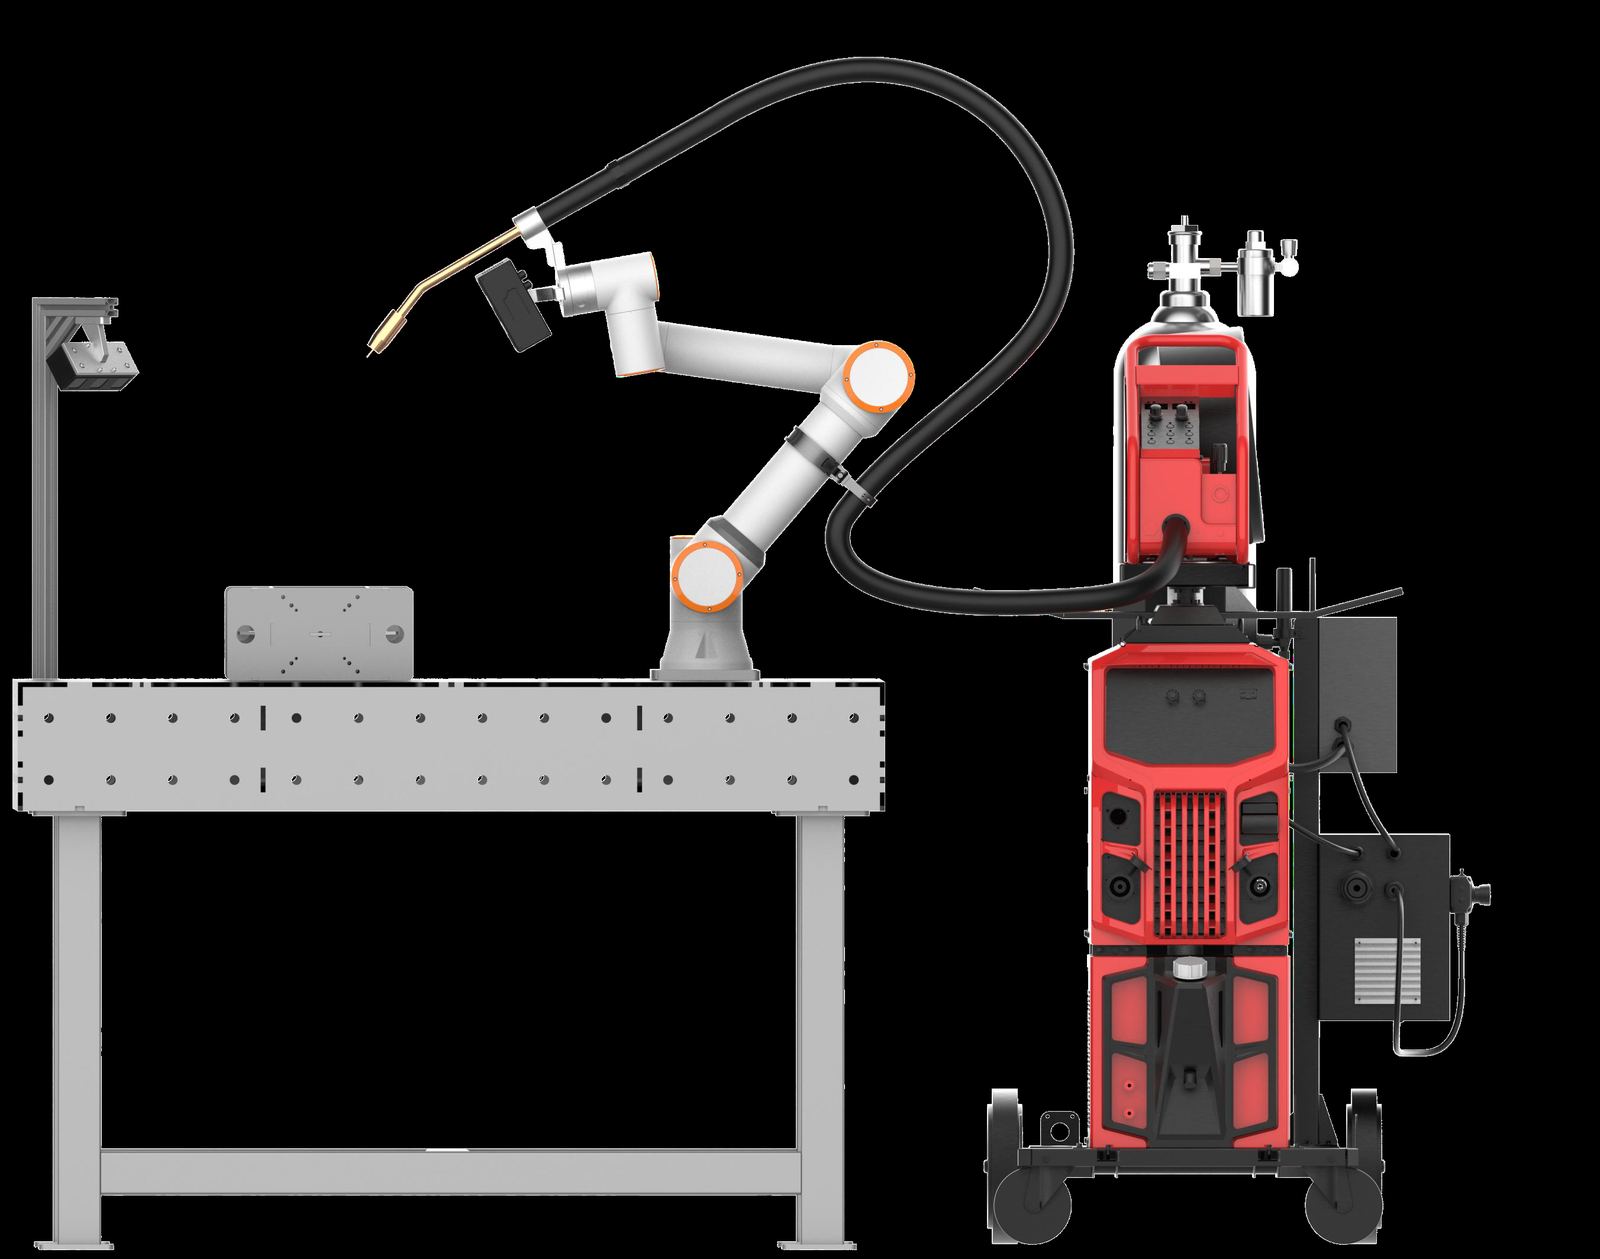
Welding: from manual teaching to AI seam planning
- 01Mobile welding — about 2 minutes to deploy, following workpieces across shipyards and steel-structure sites.
- 023D vision, no programming — the system scans the workpiece, identifies seams and plans paths automatically.
- 03Large-workpiece welding — rail-mounted and positioner solutions cover long seams and heavy workpieces.
Trusted by leading customers in shipbuilding, steel structures, petrochemicals and heavy machinery.
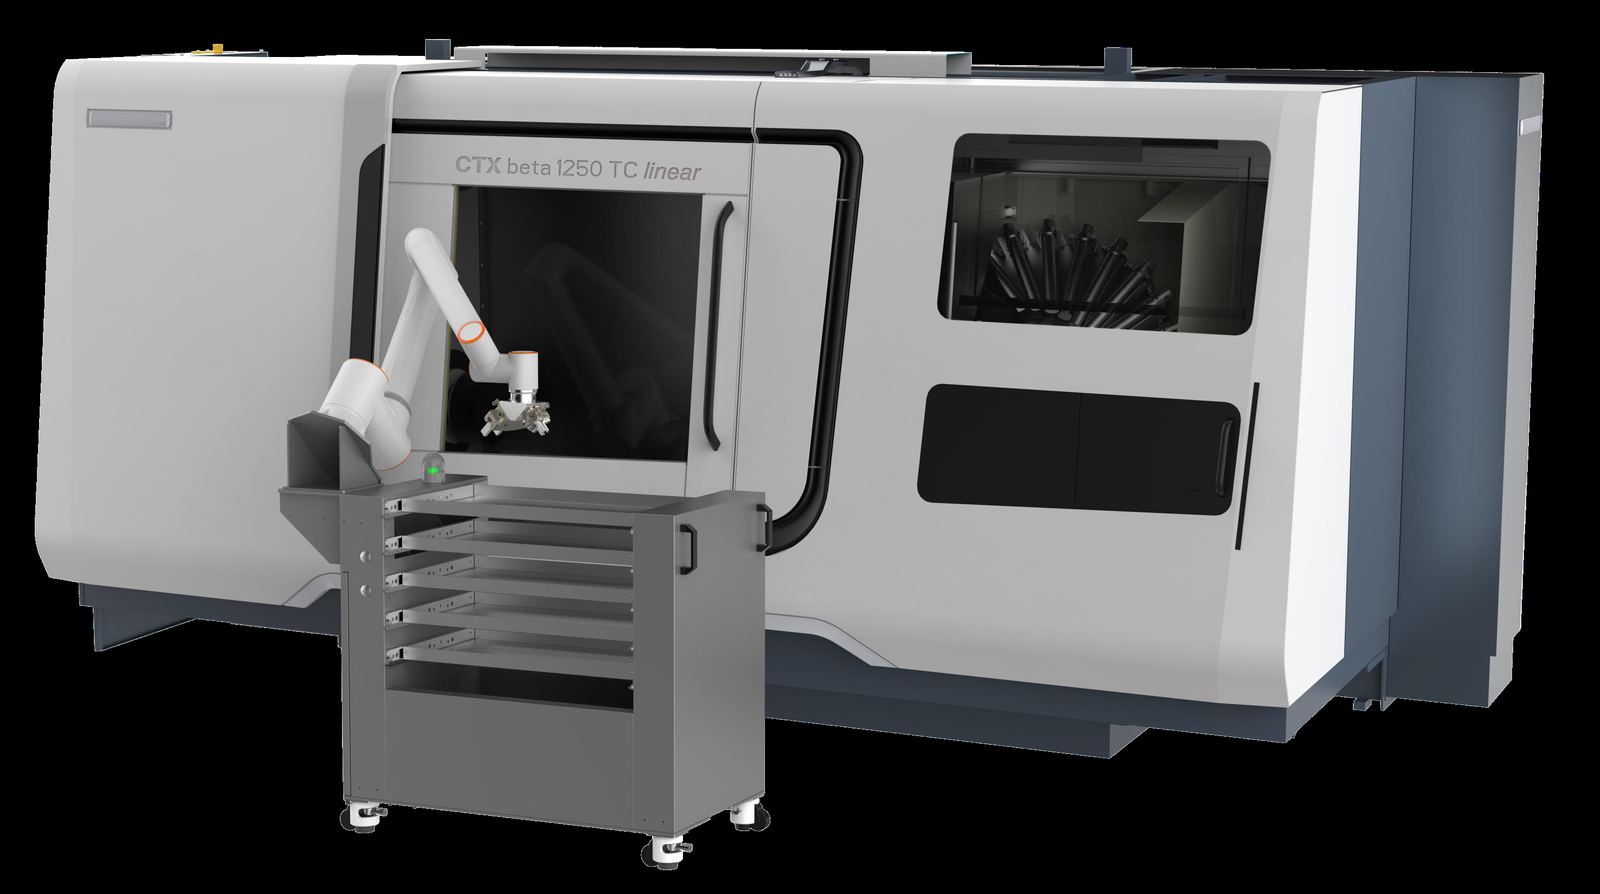
CNC machine tending: lights-out continuous production
FX10 / FX20 / FX30 arms with grippers use vision recognition and six-axis force control to tend CNC machines around the clock.
- ·24/7 unattended operation: one operator oversees multiple machines.
- ·Electric / pneumatic grippers swap quickly to suit many part types.
- ·Stable cycle times and consistent machining quality across shifts.
Typical industries: automotive parts · 3C electronics · precision manufacturing · medical devices · injection molding.
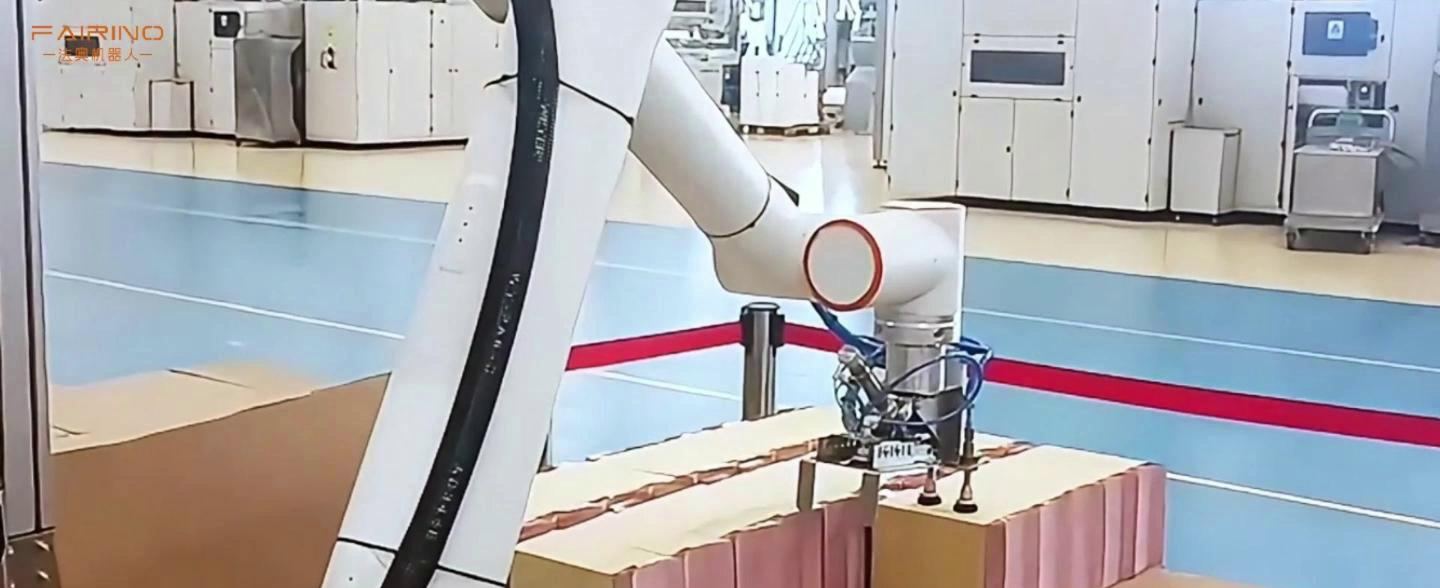
Picking: efficient vision-guided grasping
FX arms paired with 3D vision and smart grippers handle multi-SKU and random-pick scenarios with ease: suction for cartons, fingers for irregular parts, and no re-teaching when products change.
One of the fastest-growing applications by installed base, widely deployed in e-commerce fulfillment, logistics warehousing, pharmaceuticals and retail distribution.
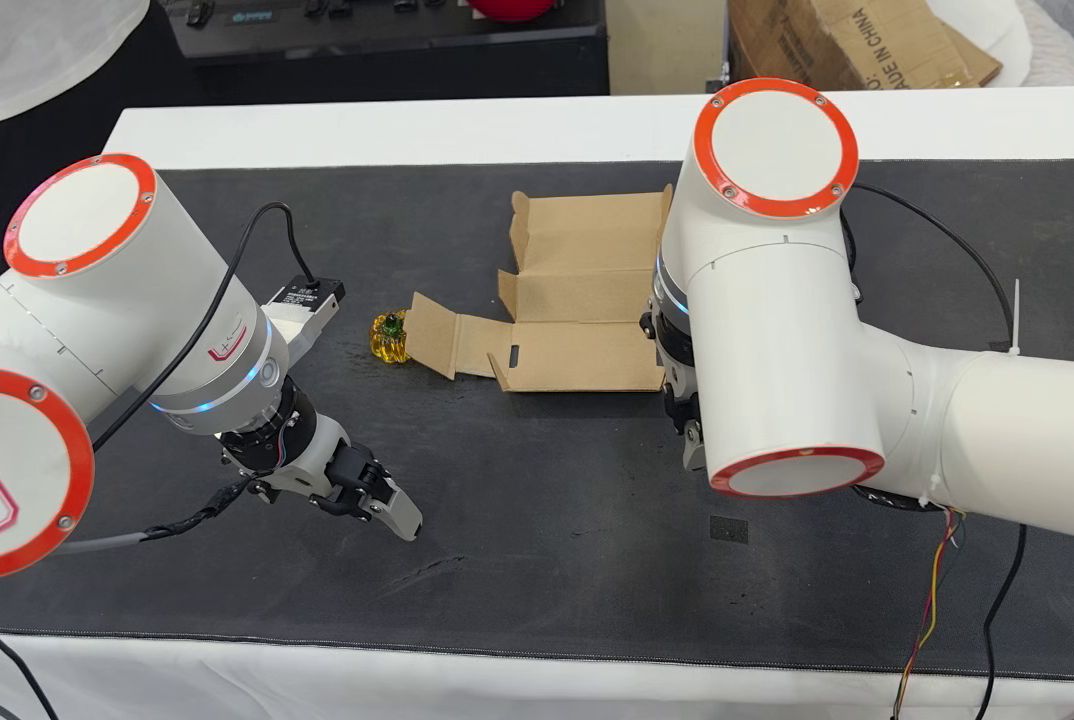
Carton packing: from human demonstration to real-robot deployment
The embodied-AI stack applied end to end — a human demonstration becomes a trained policy running on the real robot.
- 01Data collection · imitation learning — dual-arm capture of human carton-packing demos: trajectories, camera views and contact information recorded in sync to build an imitation-learning dataset.
- 02Reinforcement training — training data captured from multiple synchronized camera positions at a real workstation, with manipulation policies refined through ongoing reinforcement training.
- 03Deployment — the trained policy is deployed on the real robot and works with the dexterous hand in a closed loop to perform carton packing.
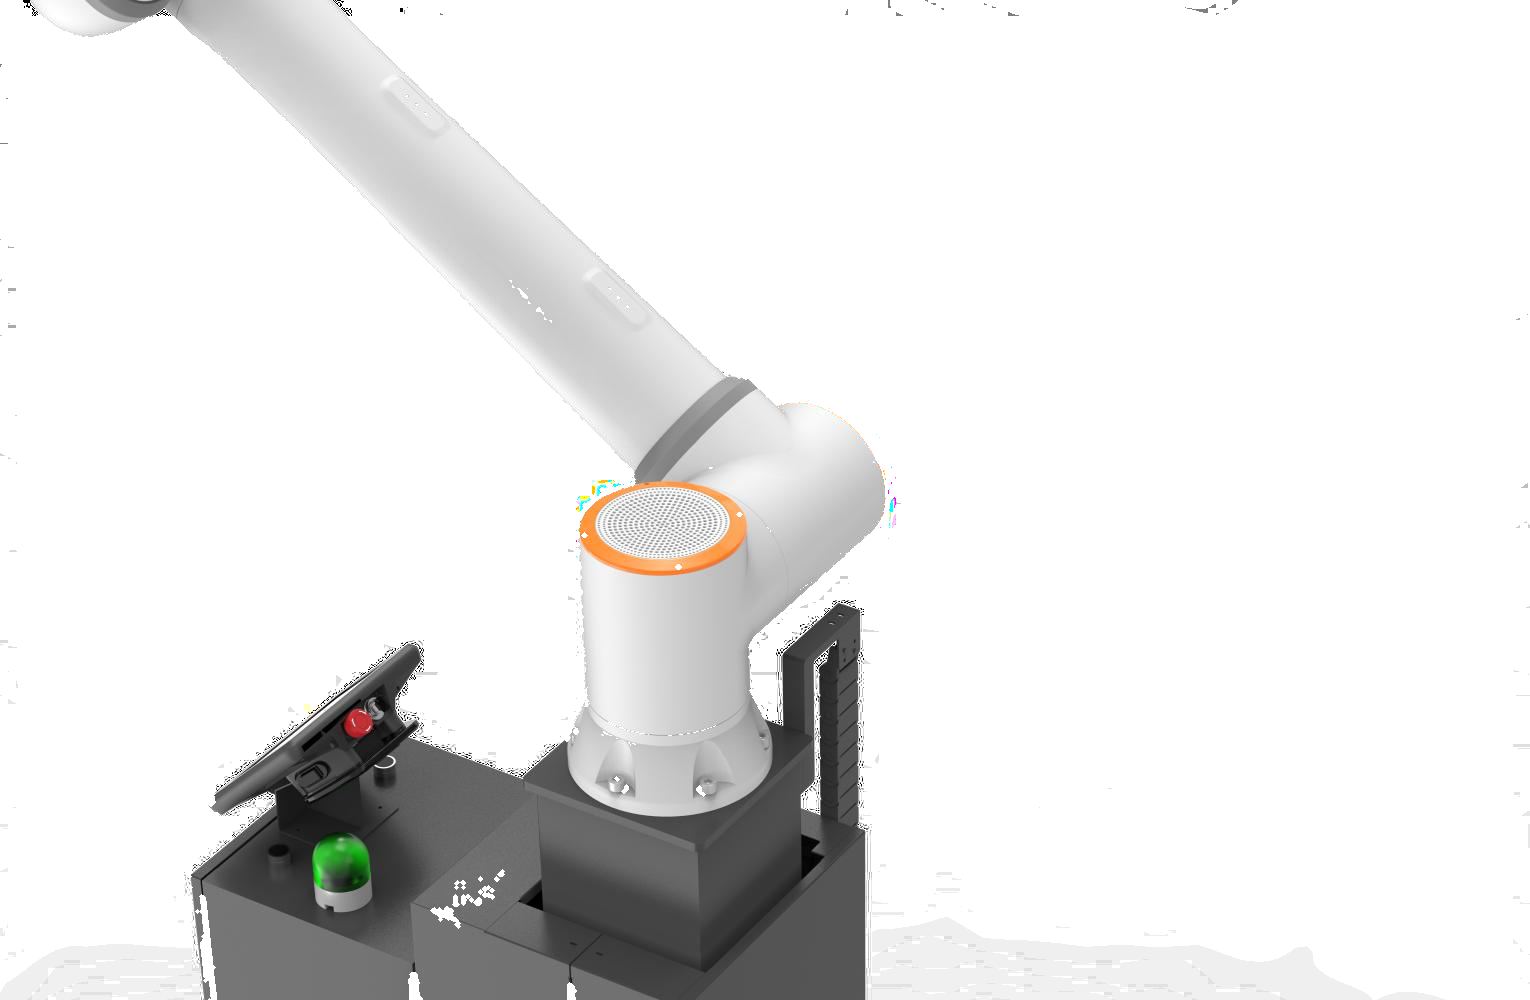
Palletizing & stacking
FX20 palletizing station, 600–800 cases/hour. Over 1,000 units shipped worldwide, serving Unilever and other plants in 5 countries.
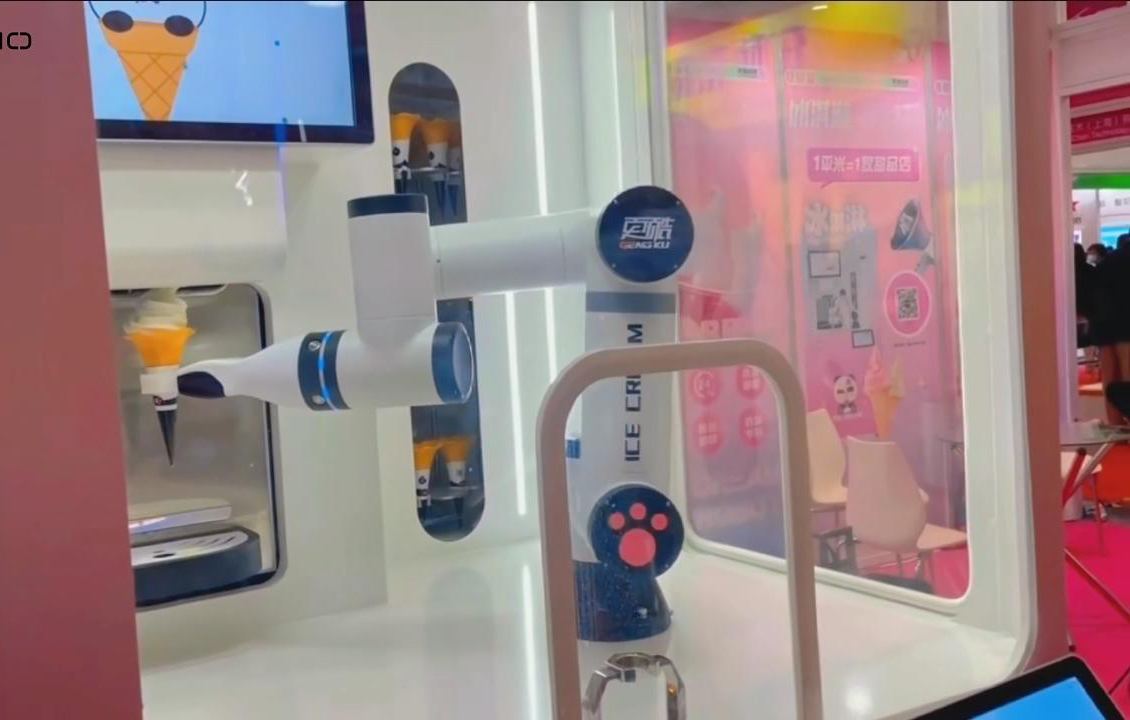
Commercial & retail
Coffee, ice-cream and food-service robots serving chain brands, attractions, campuses and office buildings.
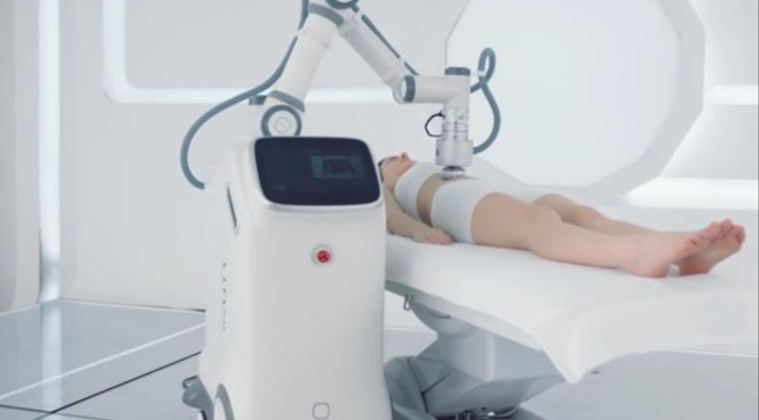
Wellness & healthcare
Six-axis force-controlled physiotherapy robots serving hospitals, rehabilitation centers and senior-living communities.
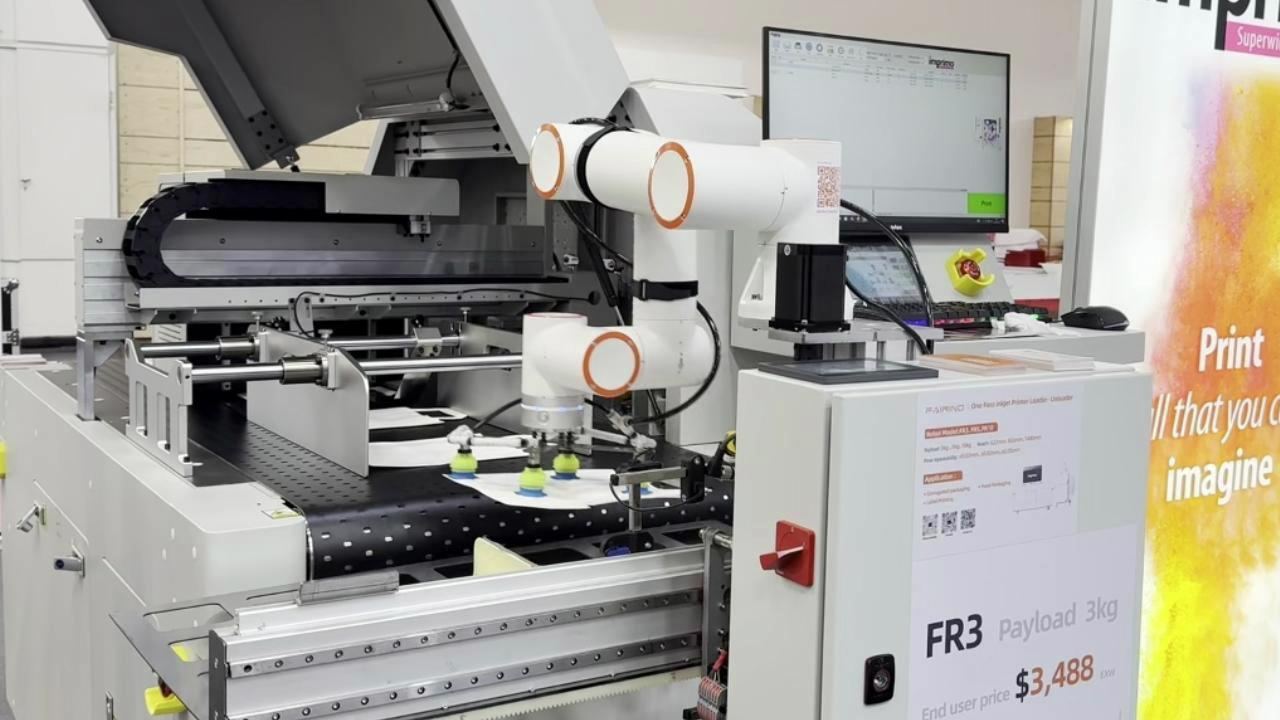
Intelligent printing & finishing
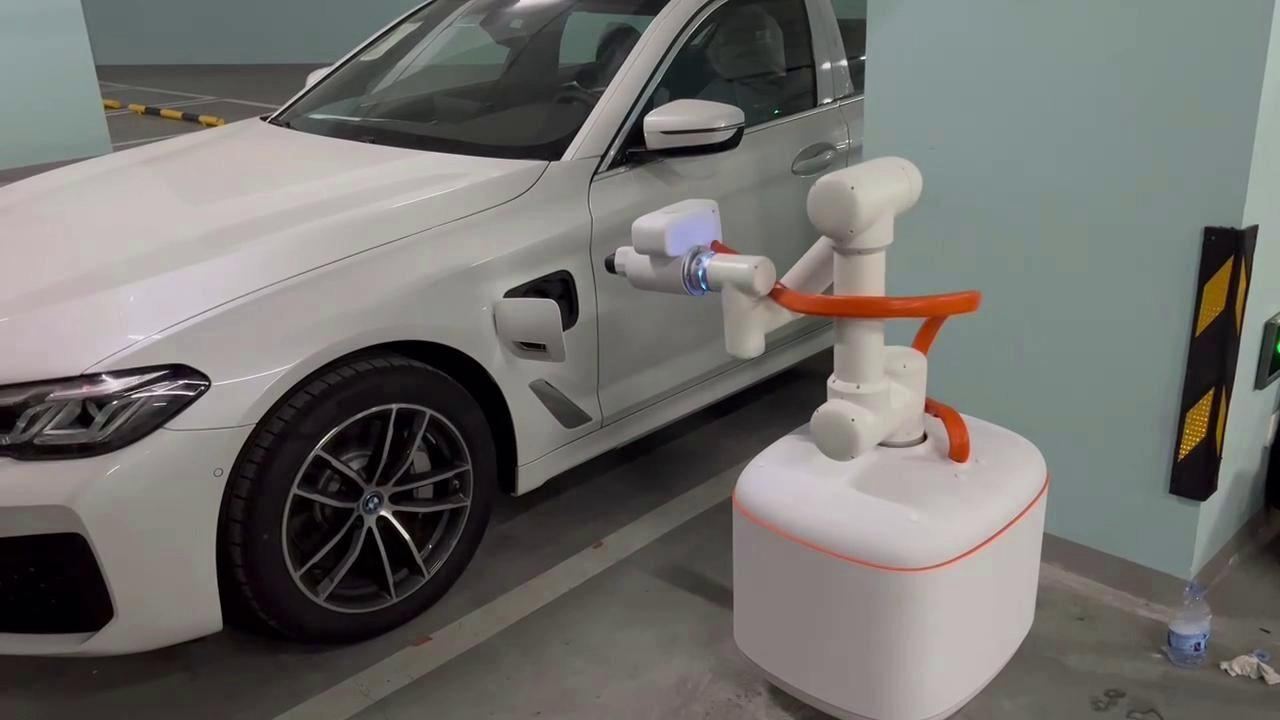
Automotive gluing & sheet metal
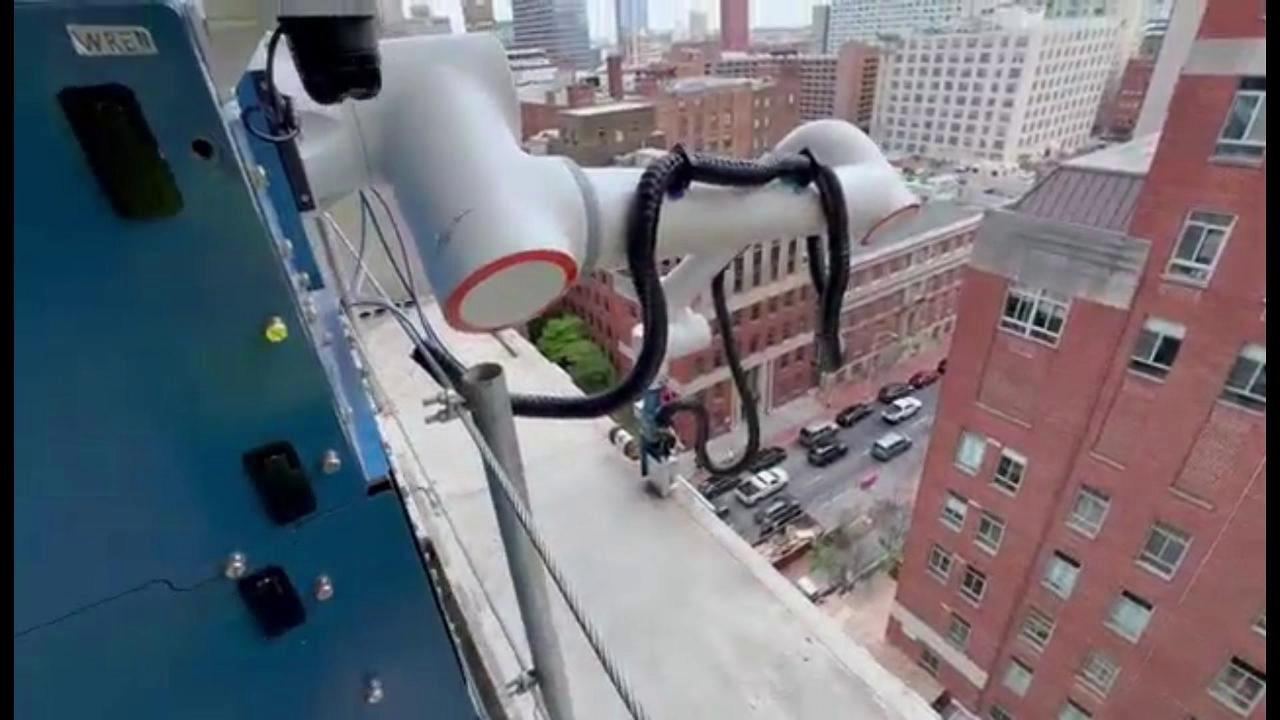
Construction & prefabricated building
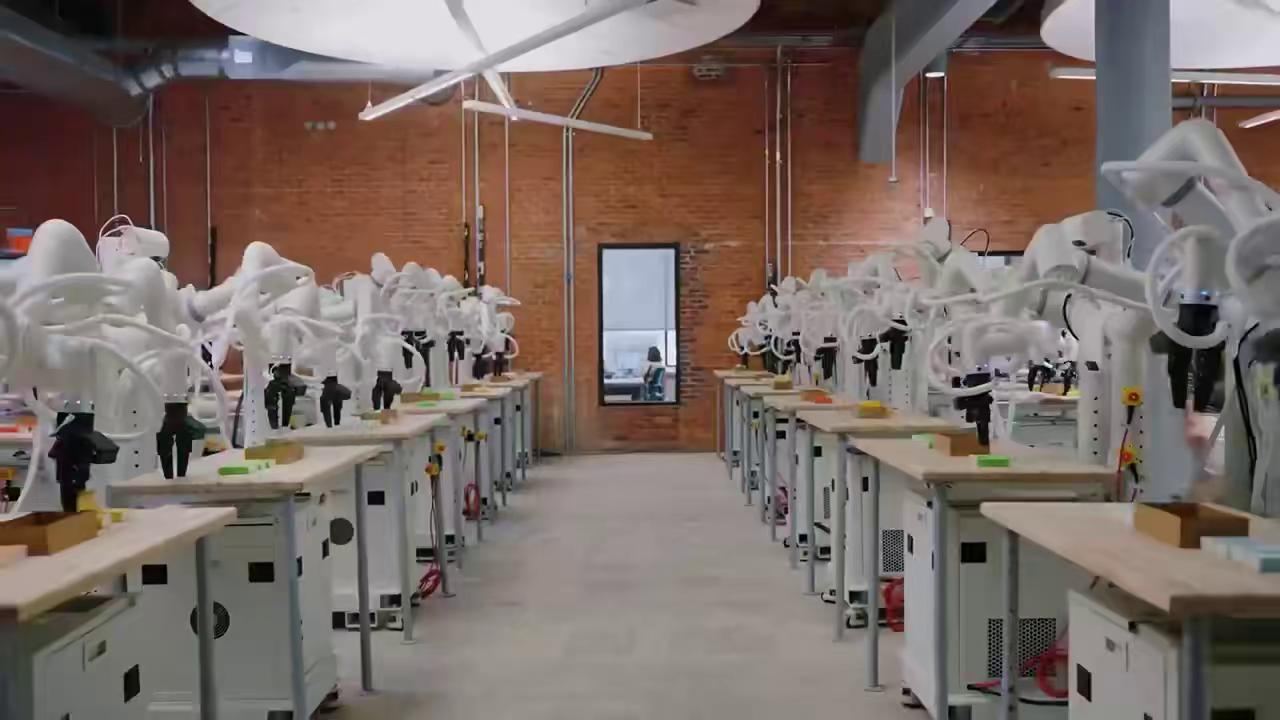
U.S. Data Factory: AI embodied-intelligence training and data collection
Rows of FX arms continuously collect real manipulation data to train embodied-AI models — a U.S. example of Faonex technology serving the next generation of intelligent robots.
Making robots accessible —
now made in America.
Cobots, 3D printing and cable manufacturing, delivered from Dallas, Texas. Tell us about your line and we'll tell you what it takes to automate it.
Faonex Robotics
10817 Sanden Drive
Dallas, TX 75238
info@faonexrobotics.com